MK1
MK1 is our mobile robot with four independently steered wheels and two YAM Ultra arms. A single-mast ball-screw lift moves both arms together.
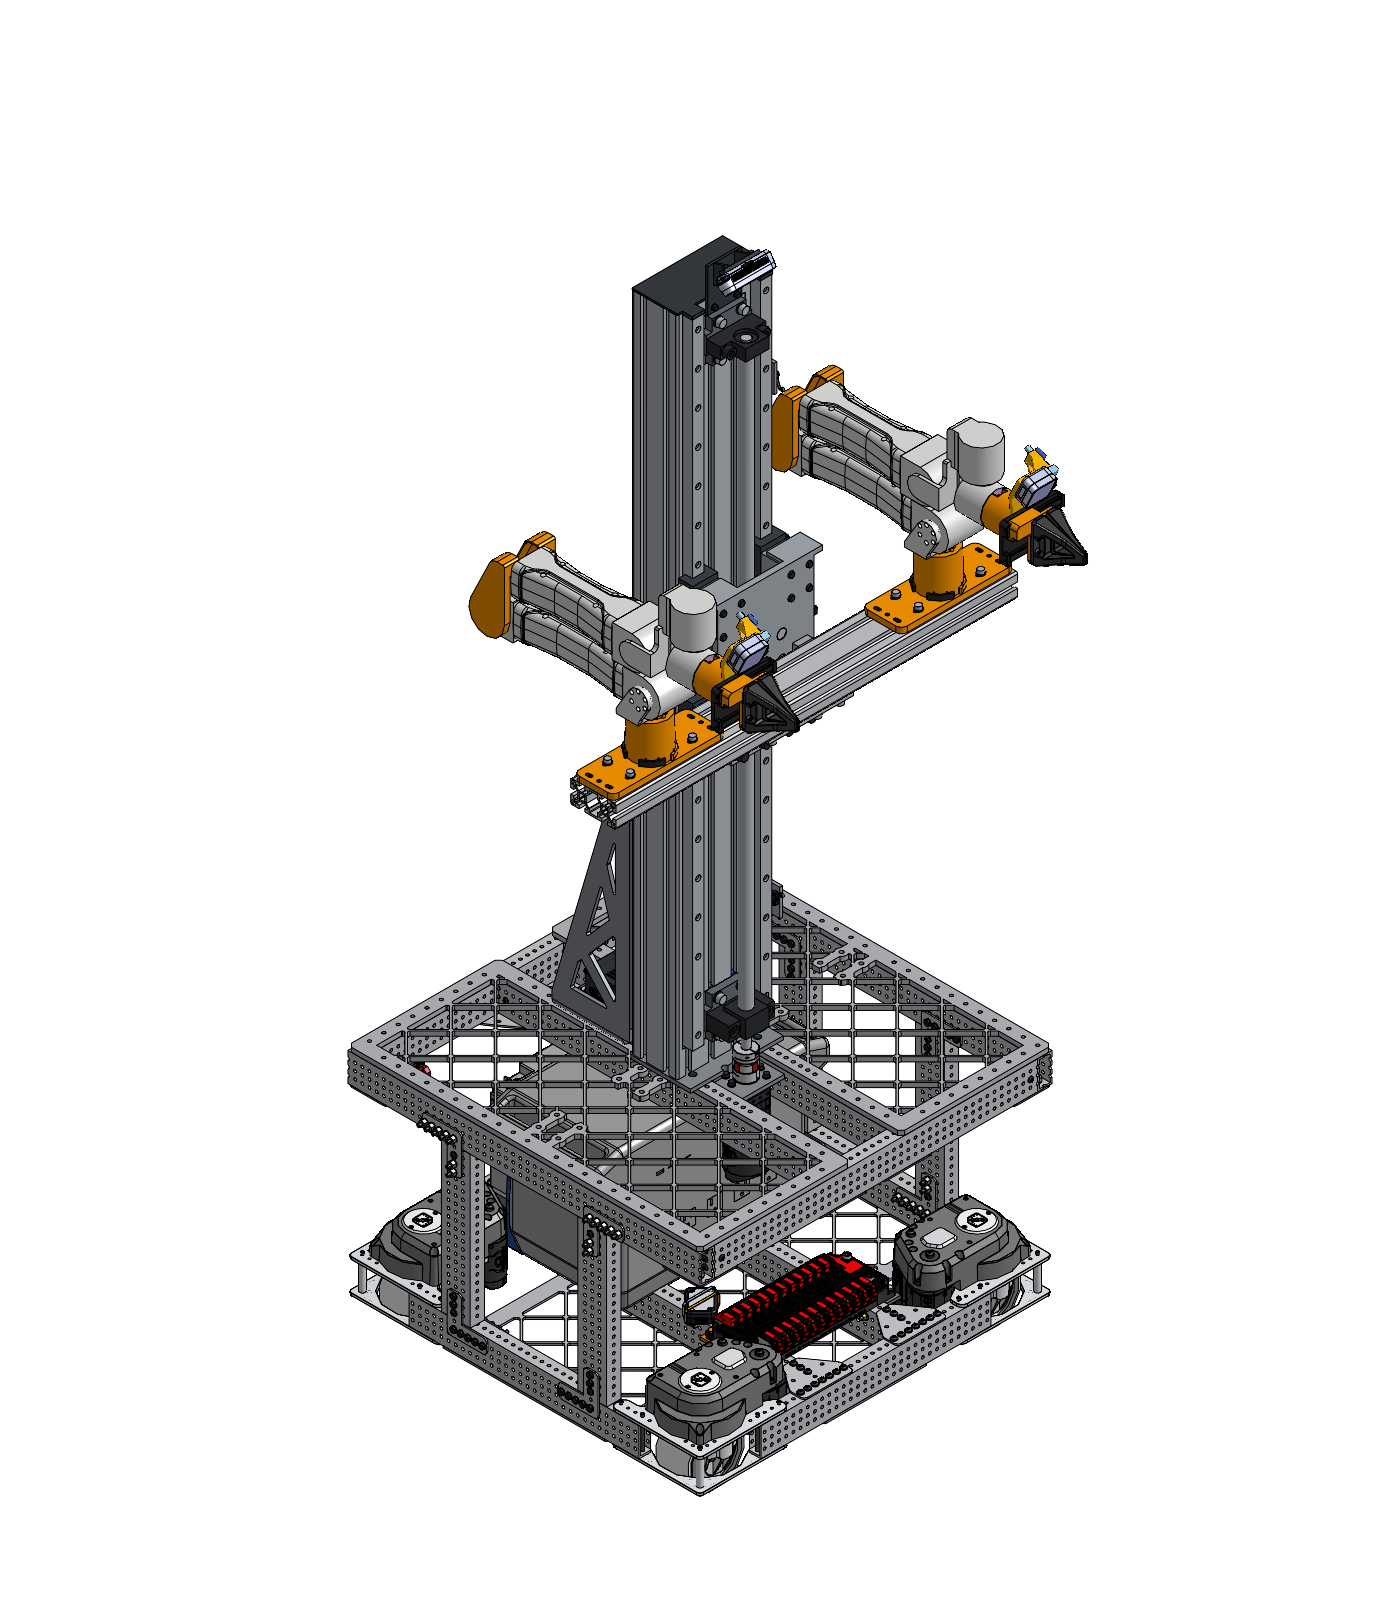
Open the current Onshape assembly
Start with swerve modules, then the frame and power connections. Each build page starts with its materials. The lift page covers the mast, drive and arm support.
This is the current CAD design. Unfinished fabrication and stop details are tracked in design status.
Last updated on