Design status
Reviewed September 23, 2026. Build the manually adjustable version first. The powered lift remains a separate development configuration. CAD checks support the prototype layout; physical fit and operation are still to be demonstrated.
Current build
| Assembly | Current selection | Remaining physical check |
|---|---|---|
| Manual-height structure | Ordered column, crossbar, supports and two DIY-drilled stock plates; arm beam starts approximately 1,145.7 mm above the floor. | Plate drilling, seating, screw engagement and supported height adjustment. |
| Arms and wrists | Delivered YAM arms; cameras above grippers on printed wrist brackets. Supplied power and USB-CAN cables retained. | Bracket fit, screw depth, cable strain relief and slow clearance sweep. |
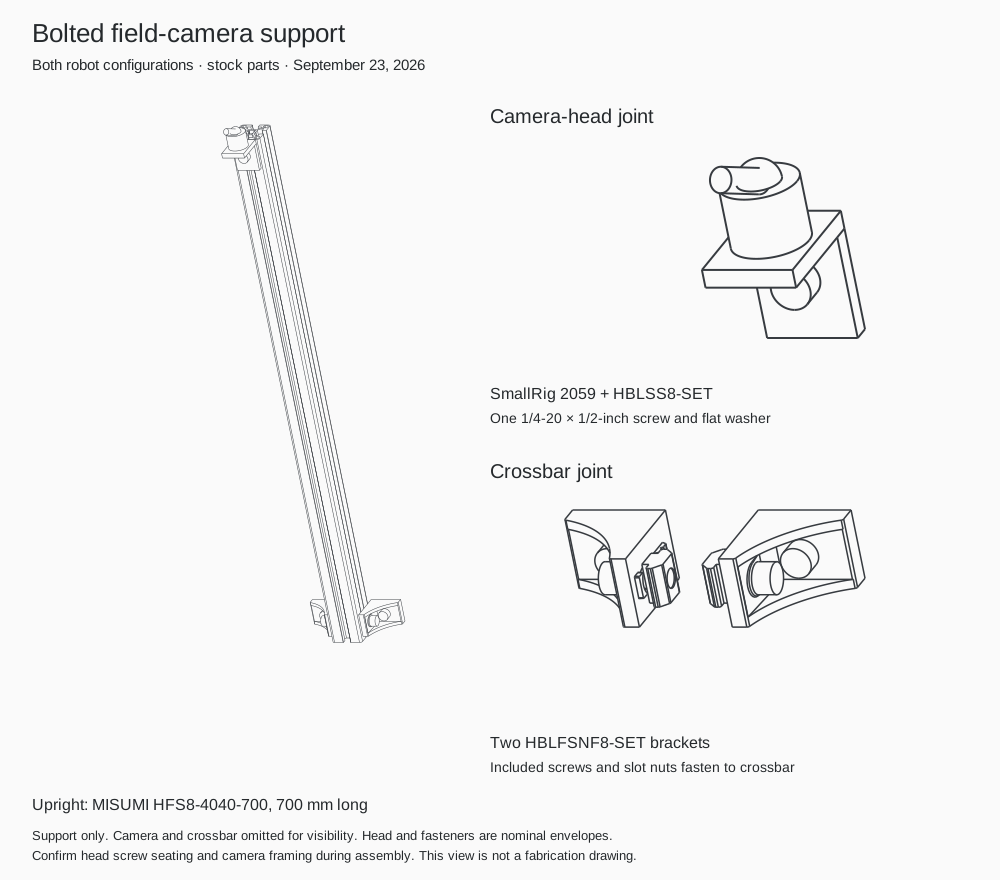
| Field camera | Bolted 700 mm MISUMI upright, two base brackets, top angle and SmallRig head on the arm crossbar in both configurations. | Head screw seating and live framing; begin approximately 684 mm above the beam, 63° down and 13° inward. |
| Camera position | Pole offset 110 mm right of center to clear the central support brackets. Nominal manual structure and parked-arm checks pass. | Full articulated motion with actual cables; the parked check is not a workspace clearance proof. |
| Base internals | User will handle mounting. Added supports and strap models are retired; included CanaKit case retained. | Actual placement, secure retention, ventilation, terminal access and steering clearance. |
| Main power | EV200 and breaker remain component references. Their proposed support prints are retired. Received precrimped leads retained. | Confirm contactor delivery and breaker variant; unpowered harness fit and control/reset wiring. |
| CAD health | Existing manual assembly: 53 features OK. Powered review: 103 features OK. | These results establish mate health, not structural capacity or physical operation. |
Open the current manual-height assembly . Manually changing height requires independent support of the arm/crossbar assembly; do not loosen its supports under an unsupported load.
Purchase changes
| Action | Item | Current evidence |
|---|---|---|
| Buy | HFS8-4040-700 x1, HBLFSNF8-SET x2, HBLSS8-SET x1 | $30.64 total; September 24 shipment shown for upright, destination arrival unresolved. |
| Buy | SmallRig 2059 two-pack x1; Marysino B0DH35F2TQ screw-set pack x1 | $22.98 total; one head and one screw/flat washer used. Amazon same-day head option and September 24 screws shown to 94158; confirm checkout. |
| Buy | One Plugable USB3-HUB7C powered hub | Last verified: $39.95, September 24 to 94158. User rejected the old hub. Reuse supplied camera/YAM cables where they reach. |
| Two wrist brackets | Nine added internal-support prints are retired and removed from active deliverables. | |
| Retire | Earlier custom field-camera supports and head | Use the stock upright and bracket kits listed above. No custom camera plate or field-camera print. Retire the TL283 clamp; preserve previous hardware as spares. |
Camera mount and replacement hub total $93.57 before shipping and tax at the last verified prices, not purchased. Proposed PowerTye straps are no longer required. Removed 22 support/strap bodies from each active Onshape assembly. The BOM quantities are retired and both strap packs are removed from the cart. Arrival estimates can change at checkout. Existing purchase and receipt history remains in the canonical BOM; no cancellation or return is currently requested by these selections.
First-week sequence
| When | Work | Dependency |
|---|---|---|
| September 23-25 | Order remaining stock parts; print mounts; prepare rails and the two stock plates. | Confirm actual deliveries and correct drawing revisions. |
| September 25-27 | Assemble manual column, crossbar, arms and camera. Connect cameras and adapters individually. | Supported assembly, secure joints and cable slack. |
| September 27-28 | Complete unpowered wiring checks and stationary device configuration. | Correct polarity, protection and a working disconnect; do not drive an unrestrained base. |
| Before base motion | Complete the user’s chosen internal mounting and check steering clearance. | Physical fit and secure retention. |
| September 29-30 | Begin low-speed base commissioning and combined camera/arm tests. | Control/reset behavior, current limits, device configuration and motion clearance established first. |
This is a conditional target, not an arrival or commissioning guarantee. The EV200 is still recorded as ordered rather than received. Base control/reset parts and their delivery remain unresolved. The base contactor does not disconnect the separately powered YAM arms. See power and CAN.
Powered lift , after the manual build
Carriage E remains the baseline. Earlier carriage D, absorber revisions and three-piece studies are historical review work, not the current fabrication list.
The live powered CAD slider now spans 680 mm, from q = 32.5 to 712.5 mm. Both switch assemblies were relocated. Both endpoints reported all 103 assembly features OK, and every starting pose was restored. Separate current-camera and motor-mount swept-envelope checks found no overlaps in their checked body sets. Cable reach, articulated arm clearance and actual stop operation still need physical commissioning; this CAD interval is not a powered operating command.
The perforated REV motor bracket and separate adapter have been replaced in the powered review by a drilled stock 6061 angle and two stock spacers. Existing screws, washers and slot nuts are reused. Tighten the two mast screws before fitting the coupling, which obstructs their straight key approach.
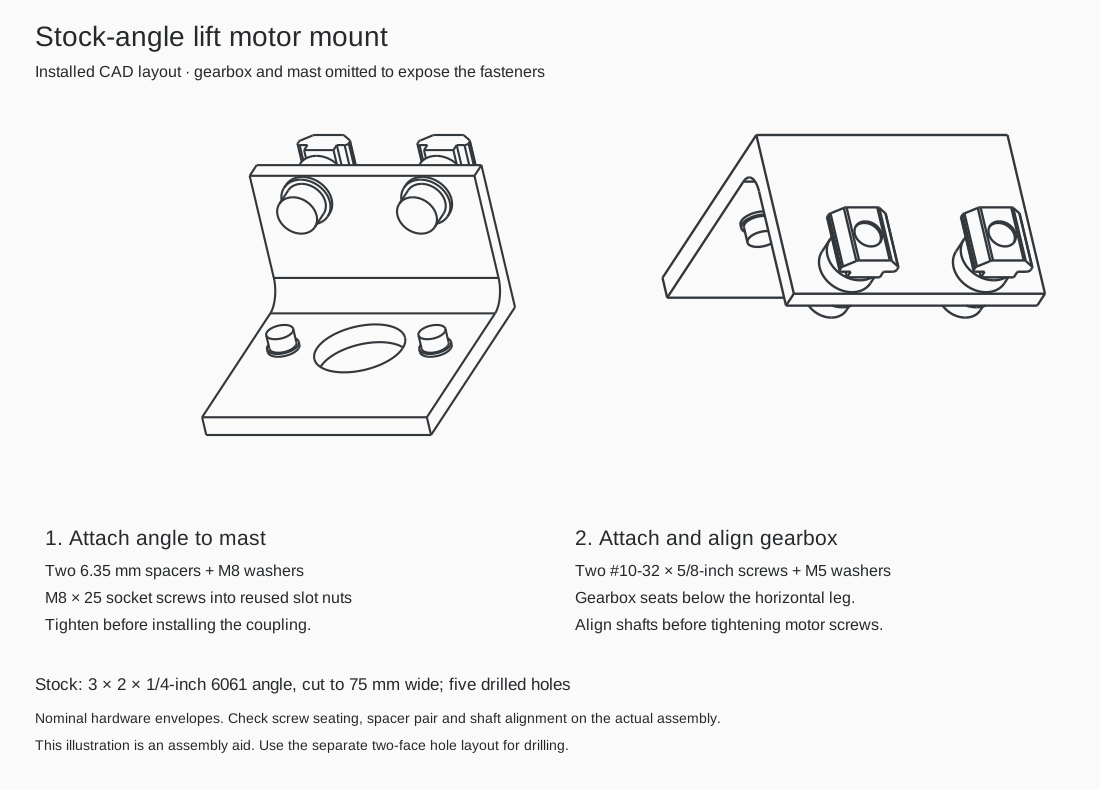
The proposed stock and tooling subtotal is approximately $72.95, or $81.92 if a 1/4-inch metal drill bit is also needed. These estimates include the angle’s quoted freight/tax but exclude other freight/tax and use a historical spacer price. Arrival is unconfirmed. The Xometry bent-steel comparison was $254.54 arriving October 1. No motor-mount purchase has been placed; new cart additions require approval after presentation.
What the checks establish
Nominal CAD geometry, selected screw engagement, ordinary load screens and supplier interfaces have been reviewed where recorded. Actual assembly, print strength/retention, unrestricted arm motion, USB concurrency and stop behavior still need physical checks. Earlier supplier calculations apply to their submitted configurations and assumptions; they do not approve later revisions automatically.
Simulation and Isaac Sim work remain deferred. Historical exports and animation assets are not evidence that the current manual-height robot has been physically validated.